Some scientific discoveries begin with a billion-dollar telescope, a spotless laboratory, or a computer powerful enough to simulate the birth of a galaxy. This one began with a dead spider curled up in a corner.
Instead of reaching for a dustpan, engineers at Rice University asked an unexpectedly productive question: Why do spiders pull their legs inward when they die? The answer led them to create a working robotic gripper from an actual spider cadaver. By inserting a needle into the spider’s body and applying air pressure, the researchers could open and close all eight legs on command.
They named the emerging concept necroboticsthe use of nonliving biological materials as functional robotic components. It sounds like a technology invented by someone who watched too many midnight horror movies, but the underlying engineering is surprisingly practical.
Research basis:
What Is a Necrobotic Spider Gripper?
A necrobotic spider gripper is a deceased spider whose natural leg mechanism has been connected to an artificial pressure source. It is not a walking zombie spider, despite what your imagination may be enthusiastically producing. The device functions more like a tiny claw-machine grabber.
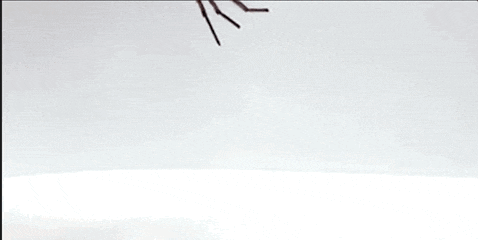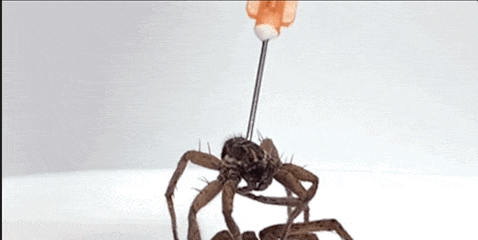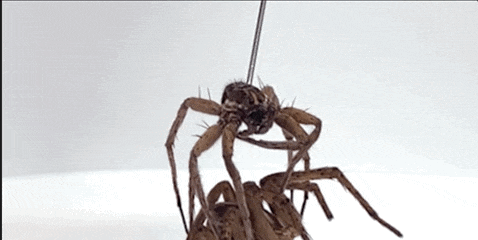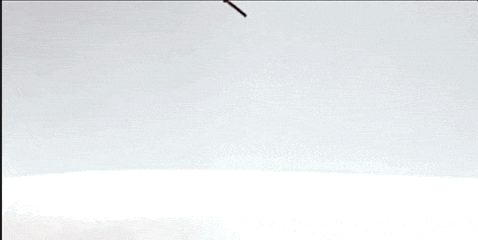
Researchers used the intact bodies of wolf spiders as ready-made actuators. A thin needle was inserted into the spider’s central body region, or prosoma, and sealed in place with adhesive. The needle was then connected to a syringe or pneumatic system.
When air entered the body, the legs extended outward. When the pressure was released, the legs curled back inward and closed around an object. The entire spider effectively became a soft, eight-fingered gripping tool with minimal fabrication.
It Uses the Spider’s Existing Hardware
Most robotic grippers must be assembled from manufactured hinges, motors, valves, sensors, wires, elastomers, and carefully molded components. The spider already comes equipped with joints, flexible membranes, gripping surfaces, valves, muscles, and eight coordinated limbs.
Nature spent hundreds of millions of years refining that package. The Rice University team simply found a highly unusual way to connect it to laboratory equipment.
Research basis:
Why Do Dead Spiders Curl Up?
The curled posture of a dead spider is not a final dramatic gesture. It is the result of how spider legs operate.
Humans move many joints with opposing muscle groups. The biceps bends the elbow, while the triceps helps straighten it. Spiders use a different arrangement in several important leg joints. Flexor muscles pull the legs inward, but outward extension relies heavily on internal hydraulic pressure.
A living spider pumps hemolymphthe arachnid equivalent of bloodinto its legs. That pressure pushes against the joints and extends the limbs. Internal valves help regulate the movement of individual legs.
After the spider dies, it can no longer maintain pressure. The flexor muscles remain unopposed, so the legs fold toward the body. The Rice engineers realized that artificial pressure might reverse the process.
From Hydraulic Animal to Pneumatic Tool
In a living spider, fluid supplies the operating pressure. In the necrobotic gripper, injected air performs the same basic job. The biological hydraulic system is temporarily converted into a pneumatic mechanism.
The process is strikingly simple. According to the research team, a functioning gripper could be assembled in roughly ten minutes once the technique had been established. There was no need to manufacture miniature joints or reproduce the spider’s complicated anatomy from scratch.
Research basis:
How Strong Are Dead Spider Grippers?
For something assembled from a spider, a needle, adhesive, and a puff of air, the gripper performed remarkably well.
The wolf spider devices could lift objects weighing approximately 130 percent of their own body mass. Researchers demonstrated them grasping irregularly shaped objects, moving small blocks, lifting another spider and removing a jumper from an electronic breadboard to break a circuit.
A tested gripper generated a peak gripping force of about 0.35 millinewtons. That number sounds tiny because the entire machine is tiny. At its intended scale, the force was sufficient for delicate manipulation.
Small Spiders May Be Proportionally Stronger
The researchers also examined how gripping performance might change with spider size. Larger spiders can exert more total force, but their strength does not increase as quickly as their body mass.
A very large spider might therefore lift a smaller percentage of its own weight. Tiny jumping spiders, by contrast, were predicted to achieve particularly impressive strength relative to their size. That makes smaller species potentially interesting for micromanipulation, where conventional mechanical parts become difficult to manufacture and assemble.
In other words, the ideal future employee for an electronics laboratory may be small, quiet and equipped with eight deceased legs. Human resources will need a new form.
Research basis:
How Long Does a Necrobotic Gripper Last?
The experimental grippers were repeatedly opened and closed to test their durability. They remained functional through hundreds of cycles, with noticeable deterioration appearing as the number of operations approached 1,000.
The main problem was dehydration. As the spider’s tissues lost moisture, flexible membranes around its joints became brittle. Cracks eventually formed, causing leaks and reduced performance.
Could a Protective Coating Help?
The team explored protective coatings, including beeswax, to slow moisture loss. Coated spider bodies lost substantially less mass over time than untreated specimens, suggesting that a sealant could extend a necrobotic device’s useful life.
Future versions might use thin polymer coatings, lubricants or other preservation methods. However, longer life is not automatically better in every application. One attraction of biological components is that they can eventually decompose instead of remaining as permanent electronic waste.
The challenge is finding the useful middle ground: durable enough to complete the task, but disposable without leaving a tiny synthetic monument behind.
Research basis:
What Could Dead Spider Grippers Be Used For?
No serious engineering team is proposing that factories replace every robotic arm with a bucket of spiders. Necrobotics is currently a proof of concept, and its most plausible applications involve small, specialized tasks.
Handling Delicate Objects
Spider legs are naturally compliant, meaning they can bend and adjust around an object instead of applying force through a rigid metal surface. This softness could help a gripper handle fragile samples without crushing them.
Potential targets might include lightweight electronic components, fine wires, soft materials or biological specimens. The hairy surfaces of spider legs may also provide useful friction when holding objects with irregular shapes.
Collecting Insects in the Field
Researchers have suggested that spider grippers might collect insects or other small specimens outdoors. A biological gripper could blend into a natural setting more effectively than a shiny mechanical claw.
Its flexible grasp could also reduce the chance of damaging a live specimen. Of course, the experience from the insect’s perspective would remain deeply confusing.
Microelectronics and Repetitive Laboratory Work
At very small scales, traditional grippers become expensive and complicated. Tiny hinges, actuators and molded parts require precise fabrication. A spider already contains an integrated gripping structure that can be activated through one central connection.
Necrobotic devices might eventually assist with repetitive pick-and-place operations, circuit manipulation or laboratory sorting. Their value would depend on better control, preservation, sanitation and standardization.
Research basis:
Why Necrobotics Matters to Soft Robotics
Soft robotics replaces rigid machines with flexible systems made from materials such as silicone, textiles, gels and elastic polymers. These robots can interact safely with delicate objects, adapt to uncertain shapes and squeeze into spaces where conventional machinery struggles.
Necrobotics pushes that philosophy in a more direct direction. Instead of copying an animal’s structure, engineers use the biological structure itself.
Bioinspired, Biohybrid and Necrobotic Systems
A bioinspired robot imitates nature. Engineers might study a gecko’s foot and manufacture an adhesive surface with similar properties.
A biohybrid robot incorporates living or active biological material, such as muscle cells. Those systems may require nutrients, temperature control and careful maintenance.
A necrobotic device uses biological material that is no longer alive but retains useful mechanical architecture. It does not need food, growth media or life-support equipment. That distinction could reduce complexity, although decomposition creates a different set of problems.
The spider gripper demonstrates that some naturally evolved mechanisms can remain mechanically useful after biological activity ends. Bones, wood, leather and natural fibers have served humans as functional materials for centuries. Necrobotics applies a robotic vocabulary to that old habit of repurposing biology.
Research basis:
The Major Limitations of Spider-Based Robots
The project is ingenious, but it is nowhere near ready to become a dependable commercial product.
Biological Parts Are Inconsistent
Manufactured components can be produced to narrow specifications. Individual spiders vary in size, age, condition, tissue strength and joint geometry. Two apparently similar specimens may not deliver identical gripping force or durability.
The Legs Initially Move Together
The prototype controlled all eight legs through a shared pressure chamber. A living spider regulates its limbs with far more precision. Independent leg control would greatly expand the possibilities, potentially enabling directed manipulation or locomotion, but it would require a more complicated interface.
Organic Material Degrades
Dehydration, decomposition and contamination limit shelf life. A practical system would need reliable preservation and storage procedures. Applications in medical, food-processing or sterile environments would face especially demanding safety requirements.
Supply Is an Awkward Question
A technology based on animal bodies requires an ethical and sustainable sourcing policy. Collecting random spiders from buildings would produce inconsistent materials, while breeding or euthanizing animals specifically for robotic components would invite understandable criticism.
Research basis:
Is Necrobotics Ethical?
The researchers acknowledged that clear ethical guidelines for sourcing and euthanizing spiders are limited. Some specimens used in the work came from biological suppliers, and the published study described the euthanasia procedure used for research materials.
Supporters may argue that humans already use nonliving biological materials in medicine, food, clothing, construction and research. A biodegradable gripper made from an animal that died naturally might appear less wasteful than a complex disposable device made from plastics, metals and electronics.
Critics respond that scientific usefulness does not erase the need for humane treatment. There is also a meaningful difference between using an animal that has already died and killing one because its body would make convenient hardware.
The sensible path is not to dismiss necrobotics as automatically monstrous or celebrate it as automatically sustainable. Researchers need transparent sourcing standards, humane procedures, clear scientific justification and an honest comparison with synthetic alternatives.
The project’s unsettling appearance may actually be useful. It forces the public and engineers to discuss where biological tools belong in technology before the field becomes more advanced.
Research basis:
A Creepy Experiment With a Serious Engineering Lesson
The Rice University spider gripper attracted attention because it looks bizarre, but its deeper lesson concerns fabrication. Engineers routinely spend enormous effort reproducing structures that already exist in nature.
Necrobotics asks whether certain biological mechanisms can be responsibly reused rather than copied. A spider offers a compact pressure chamber, articulated limbs, compliant joints and naturally textured contact surfaces in one integrated structure.
The study does not prove that dead animals will become standard robot components. It does prove that engineers can expand their definition of a usable material. The team’s work was even recognized with a 2023 Ig Nobel Prize, an award celebrating research that first makes people laugh and then makes them think.
That description fits perfectly. The first reaction is usually, “They did what with a spider?” The second is, “Waitspiders use hydraulics?” The third is checking the ceiling.
Research basis:
A Visitor’s-Eye Experience of Watching a Spider Gripper Work
The following visitor-style narrative is a descriptive reconstruction based on published demonstrations, laboratory images and reported experiments. It is not presented as a claim of firsthand attendance.
Imagine entering a mechanical engineering laboratory and seeing an ordinary syringe connected to a thin plastic tube. At the opposite end sits a wolf spider. It is motionless, legs pulled tightly toward its body in the familiar posture seen on windowsills and garage floors.
Nothing about the setup resembles a conventional robot. There are no blinking eyes, polished metal fingers or electric motors humming dramatically. The spider looks less like advanced technology and more like something the cleaning crew missed.
Then the operator presses the syringe.
All eight legs spread outward at once.
The motion is quick enough to trigger an instinctive step backward. Your brain understands that the spider is dead, but several million years of survival programming have not reviewed the laboratory paperwork. The legs extend smoothly, creating an open basket around the body.
The gripper is lowered toward a small object. Air pressure is reduced, and the legs curl inward. They settle around the target from multiple directions, adjusting naturally to its shape. The object rises from the table.
The most surprising part is not the creepiness. That arrives exactly on schedule. The surprise is how mechanically sensible the movement looks. Eight flexible legs distribute contact around the object without needing eight separate motors. The body acts as a pressure manifold, the joints behave like built-in hinges, and the legs provide compliant fingers.
A demonstration involving an electronic breadboard makes the engineering value even clearer. The spider gripper closes around a narrow jumper and pulls it from the board, interrupting the circuit. An LED switches off. It is a small task, but it shows that the device can manipulate a component that would be inconvenient for a large industrial claw.
Watching repeated cycles changes the emotional response. The first opening of the legs resembles a horror-movie effect. After the tenth, the apparatus begins to look like a clever pneumatic tool. After the twentieth, attention shifts toward pressure, gripping angles and material fatigue.
That transition may be the most valuable experience offered by the project. It demonstrates how quickly disgust can give way to curiosity when an unfamiliar mechanism is explained. The spider is no longer merely a frightening animal or an unsettling corpse. It becomes a compact lesson in fluid mechanics, biomechanics and soft robotic design.
The experience would still raise uncomfortable questions. A visitor might wonder where the specimen came from, whether it was killed for the experiment and how researchers decide which biological materials are acceptable to use. Those questions should remain present even after the technical novelty becomes fascinating.
There is also an odd sense of respect in seeing how much engineering is contained within a creature people often crush without a second thought. A manufactured copy of the spider’s gripping system could require numerous parts and fabrication steps. The original mechanism grew through ordinary biological development.
By the end of the demonstration, the spider gripper remains creepy. It simply becomes creepy in a more intellectually productive way. You leave understanding why spiders curl up, how pressure extends their legs and why soft roboticists are interested in natural structures.
You may also leave with one additional habit: inspecting the laboratory corners before touching anything.
Narrative details grounded in demonstrations and reporting:
Conclusion
Turning dead spider legs into creepy grippers sounds like a stunt designed for viral attention. In reality, the Rice University experiment offers a thoughtful demonstration of how biological architecture can become functional engineering material.
The necrobotic gripper is lightweight, naturally compliant, relatively simple to assemble and capable of lifting more than its own mass. It also has serious limitations, including dehydration, inconsistent performance, limited control and unresolved ethical questions.
Its greatest contribution may therefore be conceptual rather than commercial. The research challenges engineers to examine natural structures not only as inspiration but also as materials that may retain useful functions after death. Whether necrobotics becomes a practical field or remains a wonderfully strange experiment, it has already succeeded in making people reconsider what a robot can be.
Note: This article synthesizes peer-reviewed research and reporting from reputable scientific, engineering and technology publications. Ethical concerns and technical limitations are included because the creepy part should never distract from the complicated part.